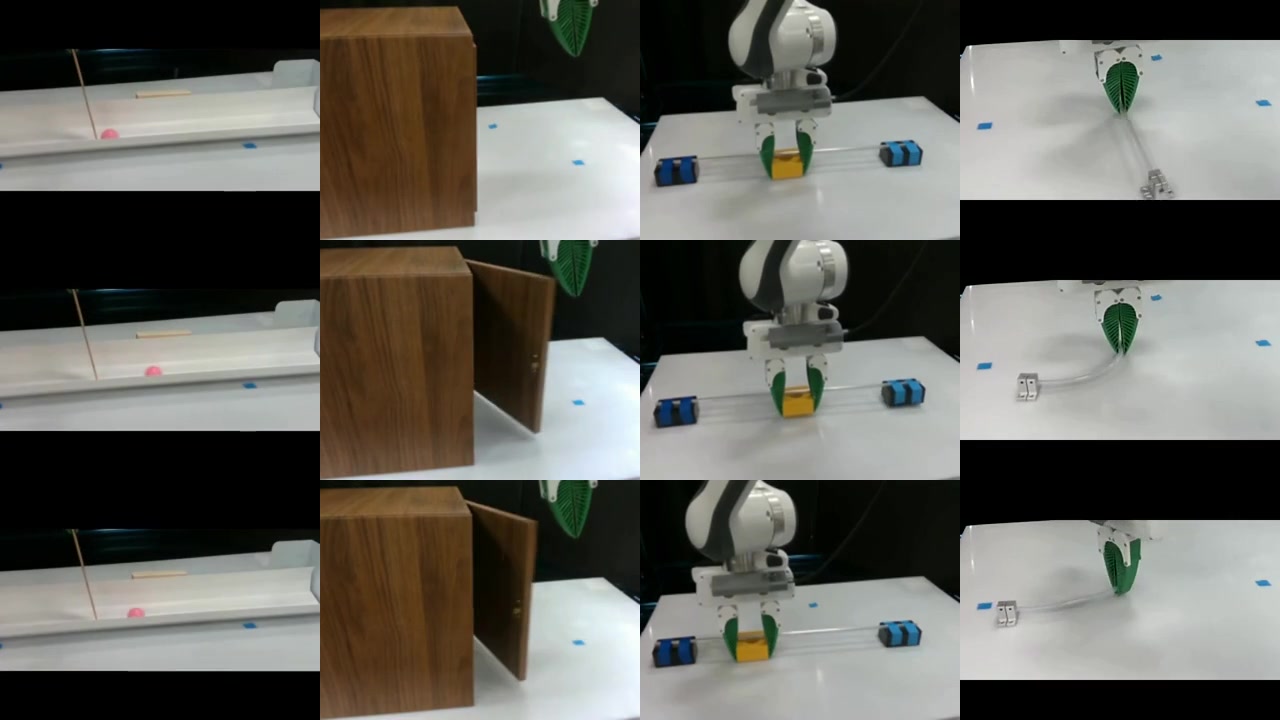
We introduce T2-z, a robotic world model augmented with a learnable environment latent that captures unobserved environmental factors without direct supervision. At test time, the world model remains frozen while a newly initialized latent is optimized from one or more interaction trajectories, adapting predictions and action selection to unseen environmental configurations. Across seven simulated settings and four real-world robotic tasks, T2-z improves world prediction and downstream action success while revealing structured latent representations of environmental variation.
@article{zhou2026t2z,title={{T2-z}: Test-Time Optimization of Environment Latents for Robotic World Models},author={Zhou, Chenyuan and Hong, Yining and Huang, Huang and Jiang, Yunfan and Huang, Wenlong and Held, David and Guizilini, Vitor Campagnolo and Wang, Yue and Li, Fei-Fei and Wu, Jiajun and Guibas, Leonidas and Choi, Yejin},journal={arXiv preprint arXiv:2610.22364},year={2026},month=oct,}